Oxygen
PREEMPT_RTThreaded interrupt handling, preemptible kernel paths and standard POSIX / Linux APIs. The simplest route when latency targets can be met within the Linux ecosystem.
Explore the distribution →REAL-TIME LINUX • NXP i.MX • YOCTO LTS
LinRT delivers embedded Linux BSPs with a choice of native Linux real-time performance, Xenomai 3 compatibility or a compact Xenomai 4 / EVL real-time core — backed by a shared cybersecurity readiness approach.
01 / Real-time approaches
All three solutions run Linux, but they make different engineering trade-offs. The right choice depends on measured worst-case latency, driver paths, application interfaces and long-term software requirements.
Threaded interrupt handling, preemptible kernel paths and standard POSIX / Linux APIs. The simplest route when latency targets can be met within the Linux ecosystem.
Explore the distribution →A separate high-priority real-time execution stage with mature Xenomai APIs, RTDM drivers and optional compatibility skins for selected legacy applications.
Explore the distribution →Dovetail connects Linux and the EVL core; libevl exposes dedicated real-time services to C/C++ applications requiring predictable out-of-band execution.
Explore the distribution →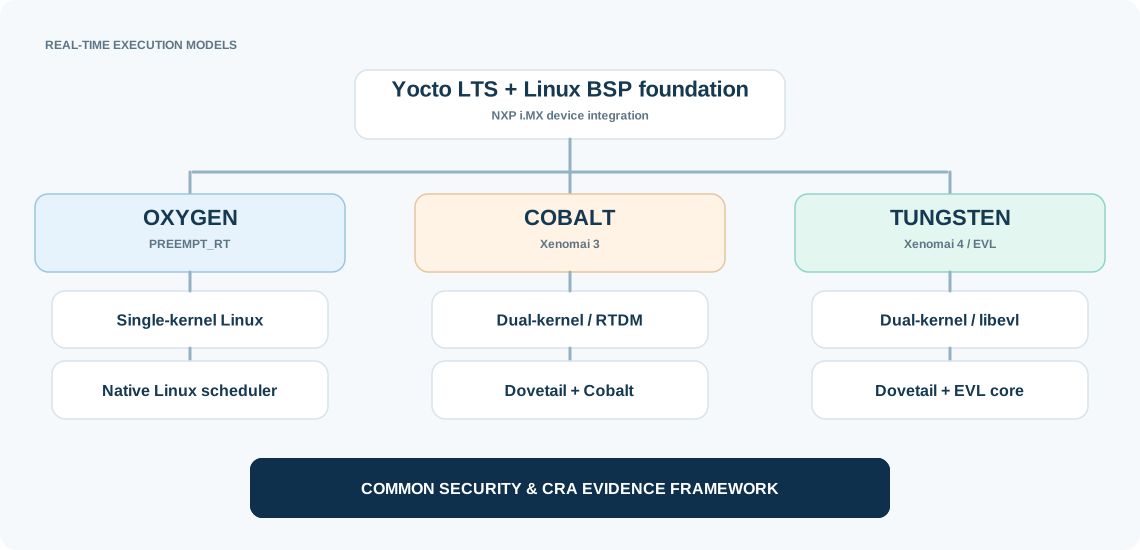
02 / Choose your architecture
| Architecture | Oxygen | Cobalt | Tungsten |
|---|---|---|---|
| Architecture | PREEMPT_RT in Linux | Dovetail + Xenomai 3 Cobalt | Dovetail + Xenomai 4 EVL |
| Application interface | POSIX, pthreads, Linux system calls | Xenomai POSIX / native; legacy skins where supported | libevl API and EVL descriptors; Linux for non-RT work |
| Critical driver approach | Mainline Linux drivers; review IRQ/thread/DMA behavior | RTDM; RTnet on qualified configurations | EVL-aware out-of-band paths as required |
| Main advantage | Maximum Linux compatibility and straightforward integration | Existing Xenomai deployments and legacy migration | Compact scalable real-time execution with Linux alongside |
| Main trade-off | Latency depends on full Linux workload and platform tuning | Specialized APIs/drivers and greater integration effort | ABI and driver porting; not a drop-in Xenomai 3 replacement |
03 / YOCTO + LINUX + QT LTS
The LinRT 5.x LTS line advances toward CRA Ready with LinRT 5.3, followed by a Wrynose-based LinRT 6.x LTS generation introducing planned i.MX95 support.
LinRT 5.3 is planned for Q4 2026 as the CRA-Ready evolution of the LinRT 5.x LTS family, on Yocto 5.0 Scarthgap LTS. BSP security controls and traceable validation evidence are the delivery goals; the separate customer CRA Certification Kit is planned for early 2027 alongside LinRT 6.x LTS.
LinRT 6.x LTS is planned for Q1 2027, targeting Yocto 6.0 Wrynose LTS, Linux 6.18 LTS and Qt 6.12 LTS. NXP i.MX95 SoM support is announced as part of this generation, subject to configuration-specific qualification.
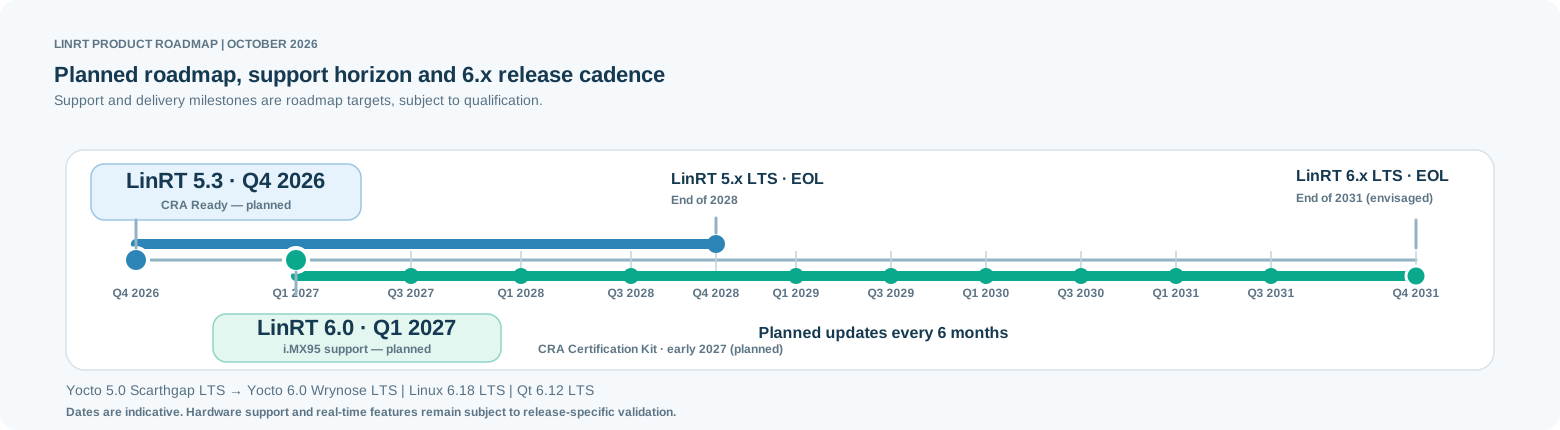
LinRT 5.x LTS uses Yocto Project 5.0 “Scarthgap” LTS, with Linux 6.6 / 6.12 LTS variants according to target and distribution. LinRT 5.3 (product version, not Yocto 5.3) is planned for Q4 2026 as CRA Ready.
LinRT 6.x LTS is planned for Q1 2027, targeting Yocto Project 6.0 “Wrynose” LTS, Linux 6.18 LTS and Qt 6.12 LTS. Support for NXP i.MX95 is planned with this release, subject to qualification for each BSP variant.
04 / NXP i.MX
Reference and target hardware families. Final support must be confirmed per distribution, SoM vendor, board design and kernel branch.
Long-lived ARM32 platforms, headless control and legacy migration; check current kernel / driver qualification.
ARM64 edge devices, multimedia, industrial HMI and real-time application integration.
Low-power industrial edge systems; SoC-specific timing and I/O qualification required.
Support announced with LinRT 6.x LTS. Board support, graphics and real-time kernel/driver compatibility require distribution-specific validation.
05 / CYBER RESILIENCE ACT
The proposed LinRT CRA-Ready BSP and CRA Certification Kit aim to make product-level cybersecurity assessment more repeatable, with evidence tied to a defined software image and hardware configuration.
Pinned sources, build configuration, package provenance
SBOM, CVE / VEX review, attack-surface and update evaluation
Hardening, boot chain and update verification, regression tests
Requirements map, test reports, support assumptions, customer handover
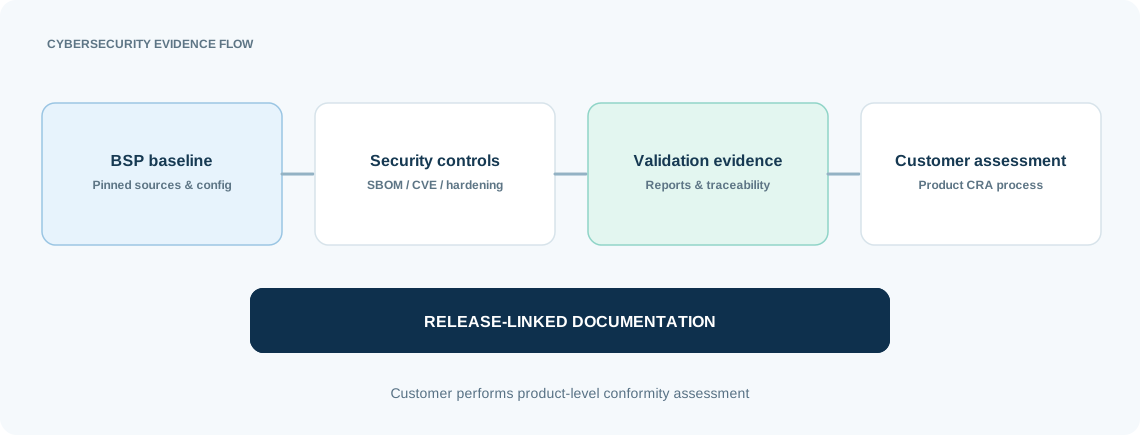
Planned for early 2027 alongside the initial LinRT 6.x LTS release, the CRA Certification Kit is designed to help manufacturers turn BSP-level cybersecurity controls into traceable evidence for their own product conformity assessments.
Software Bill of Materials, CVE/VEX workflows and component traceability for a defined BSP build.
Reusable hardening checks, boot and update assessments, and repeatable validation procedures.
Requirements-to-tests mapping, result templates and evidence package structures for customer integration.
The Kit supports a product-specific Cyber Resilience Act conformity process; it is not a CRA certificate and does not replace the manufacturer’s risk assessment or legal responsibilities.
06 / Distributions
Start from your software architecture and real-time constraints, then select the appropriate LinRT path.
Threaded interrupt handling, preemptible kernel paths and standard POSIX / Linux APIs. The simplest route when latency targets can be met within the Linux ecosystem.
Explore the distribution →A separate high-priority real-time execution stage with mature Xenomai APIs, RTDM drivers and optional compatibility skins for selected legacy applications.
Explore the distribution →Dovetail connects Linux and the EVL core; libevl exposes dedicated real-time services to C/C++ applications requiring predictable out-of-band execution.
Explore the distribution →Discuss SoM support, system integration, real-time driver architecture and the scope of the LinRT CRA-Ready roadmap.
Technical references
Technical baseline and upstream documentation used for this presentation. Product scope and availability must be confirmed with LinRT.